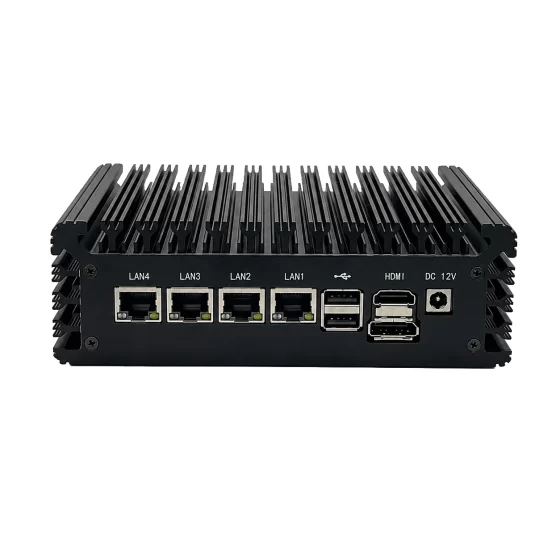
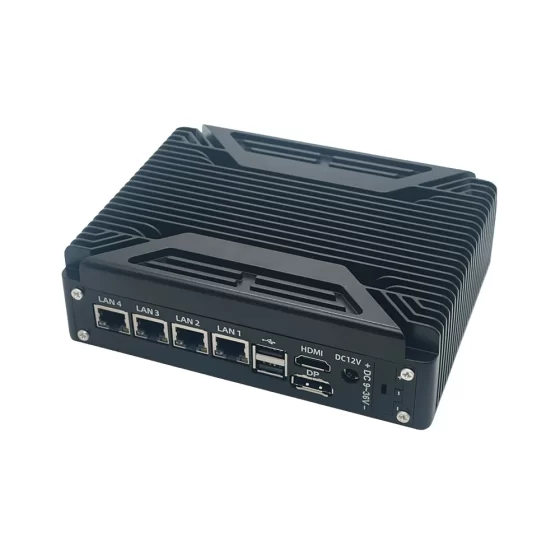
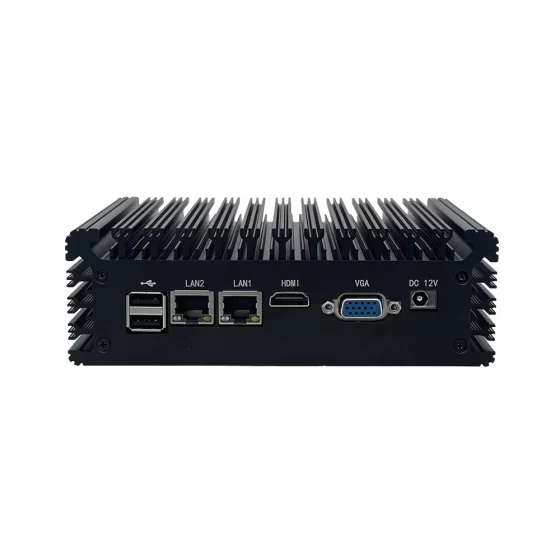
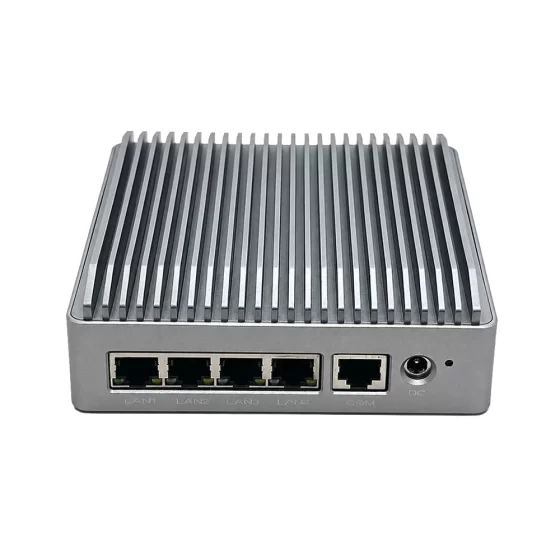
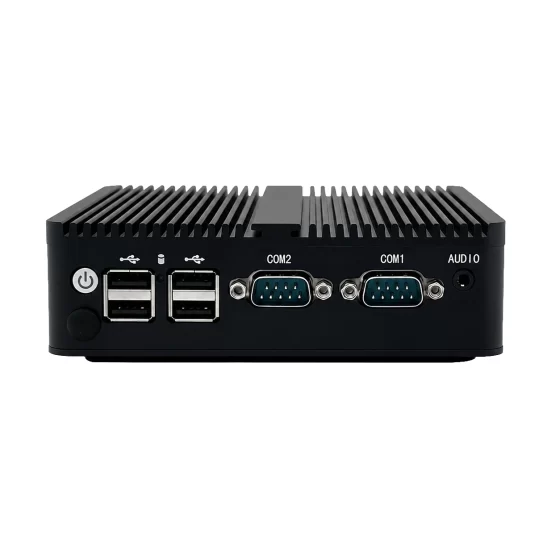
CoreIPC工业计算解决方案

移动机器人工业电脑: 适用于 AGV 和 AMR 边缘计算的移动机器人 IPC
执行摘要
A mobile robot ipc provides the industrial computing foundation for AGV and AMR navigation, 传感器融合, 机器人控制支持, 边缘AI感知, 车队通讯, 安全监控, 数据记录, 和移动自动化系统中的实时决策.
现代移动机器人在仓库中得到广泛应用, 工厂, 物流中心, 医院, 实验室, 智能零售设施, 和工业服务环境. AGV 和 AMR 帮助移动物料, 送货, 支持生产线, 内部物流自动化, 并减少人工运输工作.
这些机器人需要可靠的机载计算.
基于工业计算机或嵌入式计算机构建的移动机器人工业PC可以处理来自LiDAR的数据, 相机, 编码器, IMU, 深度传感器, 超声波传感器, 电机控制器, 电池系统, 和无线通信模块. 可支持导航软件, SLAM算法, 边缘AI推理, 机器人任务执行, 远程诊断, 和车队管理通信.
Compared with standard consumer computers or office PCs, industrial computers are better suited for mobile robot deployment because they support rugged design, 紧凑的安装, low-power operation, 抗振性, 无风扇选项, wide power input, 灵活的输入/输出, 可靠的存储, 和长生命周期可用性.
This article explains how mobile robot IPC platforms support AGV and AMR applications, what deployment challenges appear in real robot systems, 解决方案架构如何运作, and which hardware features matter when selecting an industrial computer or embedded computer for mobile robot applications.
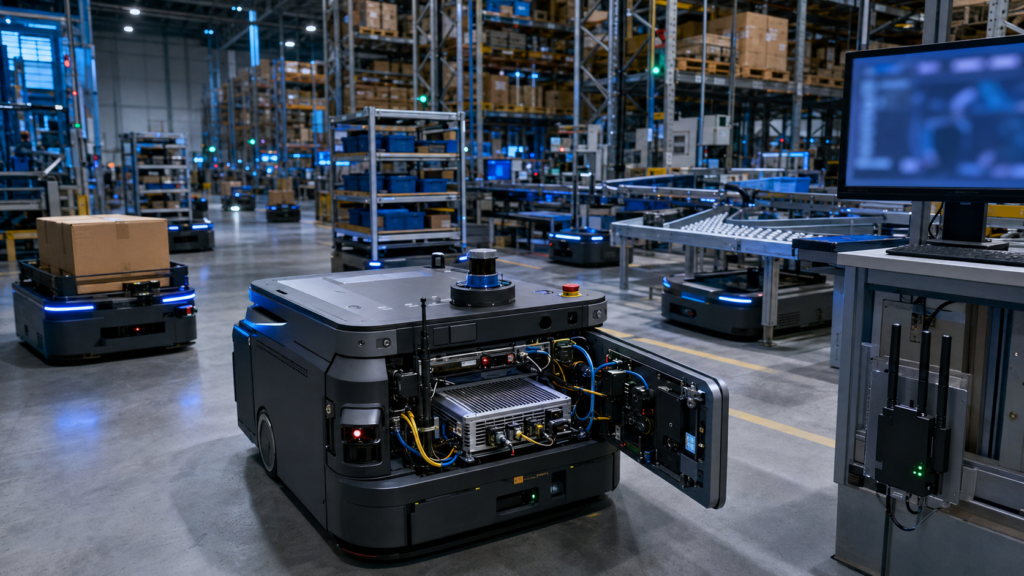
Mobile Robot Onboard Edge Computing
行业概况
Mobile Robots Are Expanding Across Industries
Mobile robots are becoming a major part of automation.
在仓库里, AMRs support picking, 补货, 运输, 排序, and inventory operations. 在工厂, AGVs and AMRs move materials between production lines, 仓库, 装配单元, 和检查站. In hospitals and laboratories, mobile robots can transport supplies, 样品, medicine, 和设备.
Common mobile robot applications include:
- AGV material transport
- AMR warehouse logistics
- Autonomous cart systems
- 移动巡检机器人
- Hospital delivery robots
- Laboratory transport robots
- Factory line feeding
- Smart retail service robots
- Mobile security robots
- Autonomous cleaning robots
- Robot fleet management
- Smart transportation support systems
These applications require stable onboard computing and reliable communication with robot sensors, 控制器, and fleet platforms.
Mobile Robots Need Local Edge Computing
Mobile robots cannot depend entirely on remote servers.
They need to make local decisions while moving through dynamic environments. A robot may need to avoid obstacles, update its route, detect people, identify objects, dock at a charging station, or stop safely when a risk appears.
A mobile robot ipc can process these tasks onboard.
它可能支持:
- SLAM navigation
- 传感器融合
- Path planning
- Obstacle detection
- Camera processing
- LiDAR data handling
- Motor control communication
- Battery status monitoring
- 无线连接
- Fleet management communication
- Local event logging
- 远程诊断
This local computing capability improves robot autonomy and operational reliability.
Industrial Computers Provide the Robot Hardware Foundation
Mobile robots operate in real environments.
They may move across warehouse floors, factory aisles, 装载区, hospital corridors, cleanroom zones, 物流中心, or outdoor-adjacent spaces.
这些环境可能包括振动, 震惊, 灰尘, 温度变化, 电源不稳定, 空间有限, electromagnetic noise, and continuous motion.
Industrial computers and embedded computers provide the rugged hardware foundation required for mobile robot deployment.
They support compact form factors, 可靠的存储, 无风扇设计选项, 灵活的输入/输出, 多网络通讯, 和长期可用性.

Mobile Robot IPC Deployment Challenges
主要挑战
Processing Multiple Sensors Onboard
Mobile robots rely on many sensors.
A typical robot may include LiDAR, 相机, 深度传感器, IMU modules, wheel encoders, 超声波传感器, bumper sensors, safety scanners, battery controllers, and motor drivers.
The mobile robot IPC must collect and process these signals reliably.
Sensor workload may include:
- LiDAR point cloud data
- Camera image streams
- Depth information
- Position feedback
- Motor status
- 电池状态
- Safety signals
- Wireless communication data
- Environmental sensor records
- Robot health information
The platform must provide enough performance and I/O flexibility for the full sensor system.
Supporting Navigation and SLAM
Autonomous mobile robots often rely on SLAM and localization algorithms.
These functions help the robot understand its position, build or update maps, avoid obstacles, and follow routes.
Navigation workloads may require:
- Real-time sensor fusion
- Map processing
- Obstacle detection
- 路线规划
- Localization updates
- Docking support
- Dynamic path adjustment
- Fleet task communication
Hardware must be selected according to the actual navigation software, robot speed, map size, 传感器数量, and response requirements.
Managing Power and Thermal Constraints
Mobile robots have limited onboard power.
The IPC must provide enough computing performance while keeping power consumption under control.
Battery-powered systems need careful balance between performance, 热, 运行时, and reliability.
重要的设计问题包括:
- How much power can the IPC consume?
- Does the robot have enough battery capacity?
- Is the enclosure ventilated?
- Is fanless operation required?
- Will the robot run continuously?
- Is GPU or AI acceleration needed?
- What is the ambient temperature range?
- How will heat be removed from the enclosure?
Power and thermal planning are critical for mobile robot IPC deployment.
Handling Vibration and Motion
Mobile robots are constantly moving.
They may travel over uneven floors, ramps, joints, thresholds, and warehouse surfaces. The onboard computer must withstand vibration, 震惊, and cable movement.
Reliable hardware design should consider:
- 坚固的外壳
- 安全安装
- Lockable connectors
- 电缆应力消除
- SSD 或 NVMe 存储
- 无风扇设计
- 稳定的电源输入
- Electrical noise protection
A standard PC is usually not suitable for this environment.
Integrating Robot Control and Fleet Systems
A mobile robot does not work alone.
It must communicate with robot controllers, motor drivers, 电池系统, 传感器, wireless networks, fleet management platforms, 仓库软件, 工厂系统, 和远程维护工具.
The onboard IPC may exchange:
- Task commands
- Route updates
- 机器人位置
- Battery data
- Error codes
- Sensor status
- Safety events
- Charging status
- 维护日志
- Fleet coordination messages
Stable communication is essential for reliable robot operation.
Supporting Long-Term Robot Product Deployment
Mobile robot products may be manufactured and deployed over many years.
Frequent computer hardware changes can create problems with operating systems, 司机, robot software, sensor SDKs, AI runtimes, 无线模块, and certification workflows.
Industrial computing platforms with lifecycle planning help robot manufacturers maintain consistent robot designs across product generations and customer sites.

Mobile Robot IPC Architecture
Mobile Robot IPC Solution Architecture
Robot Sensor Layer
The robot sensor layer includes all devices that help the robot perceive and measure its environment.
该层可能包括:
- 激光雷达传感器
- 工业相机
- Depth cameras
- IMU modules
- Wheel encoders
- Ultrasonic sensors
- Safety scanners
- Bumper sensors
- 温度传感器
- Battery monitoring devices
- Motor feedback systems
These sensors provide raw data for navigation, 安全, perception, and robot health monitoring.
Mobile Robot IPC Edge Layer
The mobile robot IPC edge layer is the onboard computing layer.
在这一层, 工业计算机或嵌入式计算机可以:
- 收集传感器数据
- Run navigation software
- Process camera streams
- Handle LiDAR data
- Perform sensor fusion
- Execute edge AI models
- 存储日志
- Communicate with motor controllers
- Send status to fleet systems
- 支持远程诊断
This layer provides the robot with local intelligence and stable computing performance.
Robot Control Integration Layer
The robot control integration layer connects the IPC with motion and control systems.
它可以与:
- 电机控制器
- Drive systems
- Battery management systems
- 机器人控制器
- 安全装置
- Charging station interfaces
- PLC
- Conveyor or dock systems
- Local HMI panels
The IPC may send commands, receive status data, monitor faults, and coordinate robot behavior with external equipment.
Communication and Fleet Layer
Mobile robots usually connect to a larger fleet or operation platform.
The communication layer may include:
- Wi-Fi modules
- 4G or 5G modules
- Ethernet service ports
- 车队管理系统
- 仓库管理系统
- Warehouse control systems
- Factory dashboards
- 云监控平台
- 远程维护工具
This layer allows operators to assign tasks, monitor robot location, 查看警报, and manage multiple robots.
Data and Security Layer
Mobile robot systems need local records and controlled access.
The IPC may store:
- Robot logs
- 传感器记录
- Navigation events
- Error messages
- Battery history
- Charging records
- Task records
- 远程访问日志
- Software configuration files
- 诊断数据
Security features may include network segmentation, 访问控制, secure remote service, 加密通讯, and configuration backup.
主要特点
Compact and Rugged Design
Mobile robot IPC systems must fit inside limited robot enclosures.
A compact embedded computer can be installed inside the robot body, control compartment, battery area, or service module.
The enclosure should support reliable mounting and protection from vibration.
Compact hardware helps robot manufacturers reduce mechanical complexity while maintaining enough computing performance for navigation and communication.
Low-Power Edge Computing
Power efficiency is important for mobile robots.
The IPC must support onboard computing without reducing robot runtime too much.
硬件选型应考虑:
- Processor power consumption
- AI accelerator requirements
- Sensor workload
- Battery capacity
- Thermal dissipation
- Operating temperature
- Continuous runtime
- Standby behavior
A well-selected embedded computer helps balance autonomy and computing performance.
Sensor and Device Connectivity
Mobile robots require many device interfaces.
有用的 I/O 选项可能包括:
- 局域网
- USB
- RS232
- RS485
- CAN or expansion interface
- 通用输入输出接口
- 数字输入
- 数字输出
- HDMI
- 显示端口
- M.2
- PCIe
- SATA 或 NVMe 存储
The final configuration should match the robot sensor suite, motor system, battery system, 和通讯模块.
Camera and Vision Support
Many mobile robots use cameras for perception, 导航, docking, 物体检测, 条码读取, or remote monitoring.
The IPC may connect cameras through USB, GigE LAN, 或扩展接口.
Camera planning should consider:
- 相机数量
- 解决
- 帧率
- Field of view
- Lighting conditions
- 存储需求
- AI model requirements
- Data bandwidth
- Processing latency
For AI-based perception, the platform may need GPU or AI accelerator support.
LiDAR and Sensor Fusion Support
LiDAR is commonly used for AMR navigation and safety-aware movement.
The IPC may process LiDAR data together with camera, IMU, encoder, and safety sensor information.
Sensor fusion helps improve localization and obstacle detection.
The computing platform should be validated with the actual robot navigation stack and sensor configuration.
可靠的本地存储
Local storage supports robot software, maps, 日志, 诊断, 人工智能模型, route data, and event records.
SSD 或 NVMe 存储通常是首选,因为它比机械驱动器提供快速访问和更好的抗震性.
存储规划应考虑:
- Map file size
- 日志保留
- 诊断记录
- AI model storage
- 任务历史记录
- 写入耐力
- 恢复工作流程
- 软件更新流程
Reliable storage improves maintainability and field support.
无线和扩展选项
Mobile robots often require wireless communication.
M.2 and PCIe expansion can support Wi-Fi, 蓝牙, 4G, 5G, 额外的局域网, 人工智能加速, 或自定义模块.
Expansion support helps robot manufacturers adapt the same computing platform to different robot models and customer environments.
This flexibility is valuable for OEM and ODM robot development.
Fanless Operation and Thermal Stability
Fanless computers are preferred in many robot systems because they reduce dust intake and remove one mechanical failure point.
然而, fanless operation requires good thermal planning.
The design should consider:
- Processor heat output
- 人工智能工作负载
- Robot enclosure material
- Heat conduction path
- 环境温度
- 连续运转
- Battery area temperature
- Mounting surface
Thermal validation should be performed under real robot workloads.
长生命周期可用性
Mobile robot products need stable supply.
Long lifecycle industrial computers help robot manufacturers maintain consistent hardware designs, 软件图像, 司机, sensor support, 和备件.
This reduces redesign work and supports multi-year robot product deployment.

AGV and AMR Fleet Operations
部署场景
AMR Navigation Computer
An embedded computer can serve as the navigation computer for autonomous mobile robots.
It can process LiDAR, 相机, IMU, encoder, and map data.
It can support localization, 障碍物检测, path planning, 车队通讯, 和远程诊断.
AGV Control Support Platform
AGVs may follow fixed paths, magnetic strips, 二维码, markers, or guided routes.
A mobile robot IPC can support onboard communication, task logging, 传感器集成, 电池监控, and connection with control systems.
This improves AGV visibility and maintainability.
Mobile Robot Vision Processing
Some robots use vision for object detection, docking, 条码读取, shelf recognition, or navigation assistance.
An industrial computer can process camera data locally and send results to the robot control system.
For AI vision, edge AI computing performance may be required.
Warehouse AMR Fleet System
Warehouses may deploy many AMRs for picking, 运输, 补货, and sorting support.
The onboard IPC communicates with fleet management systems and warehouse software.
It can report robot status, task completion, battery state, route events, and diagnostic information.
Factory Material Handling Robot
Factories use mobile robots to move parts, 工具, carts, and materials between production lines.
An embedded computer can connect the robot with PLCs, 输送机, docking stations, and factory monitoring systems.
This supports more integrated production logistics.
Hospital and Service Robot
Service robots may operate in hospitals, 办公室, 实验室, or public facilities.
The IPC can support navigation, 障碍物检测, task communication, 相机处理, and remote monitoring.
The final system should be selected according to application-specific safety and compliance requirements.
Outdoor-Adjacent Inspection Robot
Some mobile robots inspect facilities, 设备房, 公用设施区域, or semi-outdoor environments.
Industrial computers support rugged operation, 本地数据处理, 传感器集成, 和远程通讯.
Environmental and power design should be reviewed carefully for these deployments.
OEM Mobile Robot Computing Platform
Robot manufacturers can integrate industrial computers or custom embedded boards into mobile robot products.
The platform can support navigation, perception, 沟通, 数据存储, 远程诊断, 无线模块, 和客户特定的 I/O.
This helps create scalable mobile robot product lines.
商业效益
Improved Robot Autonomy
A mobile robot IPC gives robots local computing power for navigation, perception, 传感器融合, 和决策.
This reduces dependence on remote systems and improves robot responsiveness.
Better onboard computing supports more capable AGV and AMR systems.
更好的运营可见性
The IPC can collect and store robot status, location records, task data, battery information, 错误日志, and sensor events.
This information can be sent to fleet platforms, 仓库系统, factory dashboards, 或维修工具.
Better visibility helps operators manage robot fleets more effectively.
More Reliable Field Operation
Industrial computers provide rugged hardware for moving systems.
无风扇设计选项, 可靠的存储, 安全安装, 稳定的电源输入, and vibration-resistant design help reduce downtime risk.
This is important for mobile robots operating long hours.
Easier Robot System Integration
A mobile robot IPC can connect sensors, motor systems, battery modules, 相机, 无线模块, and fleet software.
This helps robot manufacturers and system integrators build complete mobile robot systems with fewer integration gaps.
Flexible I/O supports different robot designs.
Scalable Robot Product Development
A standardized industrial computing platform makes it easier to develop multiple robot models.
一致的硬件简化了软件映像, 司机, navigation stack validation, 备件计划, 和生命周期管理.
This supports OEM mobile robot product development.
Stronger Maintenance and Diagnostics
本地日志, 远程访问, health monitoring, and diagnostic records help engineers troubleshoot issues faster.
This reduces service cost and improves customer support.
Reliable storage and remote diagnostics are especially valuable for deployed robot fleets.
为什么选择CoreIPC
CoreIPC为机器人提供工业计算平台, 边缘人工智能, 机器视觉, 工业物联网, 智慧交通, 和嵌入式系统集成. For mobile robot IPC applications, CoreIPC专注于可靠的工业计算机硬件, 嵌入式计算机解决方案, compact embedded design, 灵活的输入/输出, 多 LAN 配置, camera and sensor connectivity, 无风扇部署选项, 本地存储能力, 和OEM/ODM定制支持. CoreIPC helps robot manufacturers, 系统集成商, and automation providers select computing platforms that match real deployment requirements, 包括传感器数量, navigation workload, AI inference needs, 电源输入, 安装方法, 热条件, 无线扩展, 和生命周期规划.
常见问题解答
1. What is a mobile robot IPC?
A mobile robot IPC is an industrial computing platform installed onboard an AGV, 抗微生物药物耐药性, or service robot.
It can process sensor data, support navigation, communicate with motor controllers, connect cameras and LiDAR, 存储日志, manage wireless communication, and exchange data with fleet management or warehouse software systems.
2. Why use an industrial computer for mobile robots?
An industrial computer provides rugged hardware for moving robot platforms.
可支持紧凑安装, vibration-resistant storage, 无风扇运行, 灵活的输入/输出, multiple LAN and USB ports, 稳定的电源输入, 和长生命周期可用性. These features make it suitable for mobile robots operating in warehouses, 工厂, 医院, and service environments.
3. How is an embedded computer used in AGV and AMR systems?
An embedded computer can act as the onboard computing node.
It may run navigation software, process LiDAR and camera data, communicate with motor controllers, monitor battery status, connect wireless modules, store maps, and report robot status to fleet management platforms.
4. What sensors can a mobile robot IPC connect?
A mobile robot IPC may connect LiDAR, 相机, 深度传感器, IMU, 编码器, 超声波传感器, safety scanners, bumper sensors, 电池系统, 电机控制器, 无线模块, and local service interfaces.
The exact support depends on hardware interfaces, 软件驱动程序, and robot system design.
5. Does mobile robot IPC hardware need AI acceleration?
并不总是.
Basic AGV control and simple data logging may not need AI acceleration. Advanced AMR perception, 物体检测, vision-based navigation, docking, and obstacle classification may benefit from GPU or AI accelerator support.
The final choice should be based on the actual AI workload.
6. Why is low power consumption important for mobile robot IPC systems?
Mobile robots run on batteries.
A high-power computer may reduce runtime, increase heat, and require larger batteries or more complex thermal design.
The IPC should provide enough computing performance while staying within the robot power budget.
7. Why are fanless computers useful for mobile robots?
Fanless computers reduce dust intake and remove one mechanical failure point.
They are useful in warehouses, 工厂, and service environments where robots may operate for long hours. 然而, fanless thermal design must be validated under real navigation, 传感器, and AI workloads.
8. What hardware features matter for mobile robot IPC platforms?
重要特点包括尺寸紧凑, low power consumption, 足够的CPU性能, optional AI acceleration, 多个 LAN 端口, USB, RS232, RS485, 通用输入输出接口, 扩展接口, SSD 或 NVMe 存储, 坚固的外壳, 无风扇设计, 稳定的电源输入, and wireless module support.
The final configuration should match robot workload and mechanical design.
9. Can mobile robot IPC platforms support fleet management?
是的. A mobile robot IPC can exchange robot status, task information, location data, 电池电量, 警报, and diagnostic records with fleet management systems.
It can also support remote monitoring and software updates depending on system design.
10. 部署前应该测试什么?
部署前, the platform should be tested with real robot sensors, 电机控制器, 电池系统, navigation software, wireless networks, robot workloads, 存储行为, 和长时间运行的操作.
热稳定性, vibration performance, power behavior, 通讯延迟, 远程诊断, 恢复程序也应得到验证.
结论
A mobile robot ipc is a practical foundation for AGV and AMR navigation, onboard edge computing, 传感器融合, robot perception, wireless communication, fleet integration, 本地数据存储, 和远程诊断.
By placing an industrial computer or embedded computer inside the robot platform, robot manufacturers and system integrators can connect LiDAR, 相机, IMU, 编码器, 电机控制器, 电池系统, safety sensors, 无线模块, 车队平台, 仓库系统, and monitoring dashboards through reliable onboard computing.
The right mobile robot industrial PC should be selected according to real deployment requirements, 包括传感器数量, navigation workload, AI inference needs, 功率预算, battery runtime, 输入/输出要求, 无线扩展, 存储配置, 安装方法, 振动条件, 热设计, 操作系统支持, 和生命周期规划.
CoreIPC supports mobile robot IPC projects with industrial computing platforms designed for practical AGV, 抗微生物药物耐药性, service robot, warehouse robot, 和 OEM 部署. 拥有正确的硬件基础, robot manufacturers and automation providers can build reliable, 可扩展, and intelligent mobile robot systems.
联系我们
寻找工业计算机, 嵌入式计算机, or compact IPC platform for mobile robot deployment?
联系 CoreIPC 讨论您的项目需求, 包括传感器接口, navigation workload, AI performance, 电源输入, 无线扩展, I/O needs, 存储设计, 安装方法, 振动环境, 热条件, 生命周期需求, 和 OEM/ODM 定制选项.